Personal project · Fall 2025
Two-stage cycloidal gearbox
Designing a printed two-stage cycloidal transmission through iterative testing of bearing fits, alignment, and assembly.
- My work
- Gearbox design, bearing selection, and 12 printed iterations
- Result
- 84:1 measured overall reduction
- Status
- Motion demonstrated; output torque not measured
The project
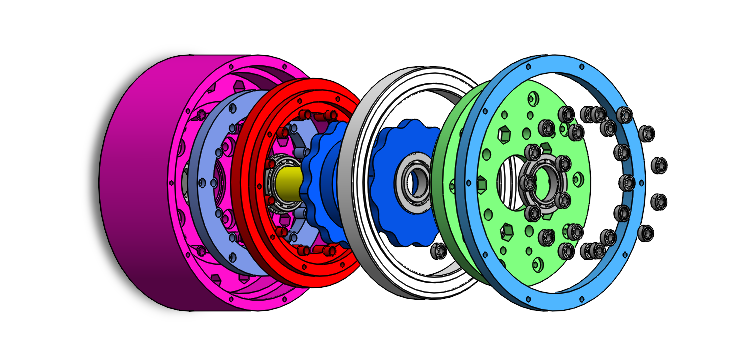
I investigated a different way to use a cycloidal gearbox: remove the inner lobes used in the traditional design, pin two cycloidal disks together in a two-stage arrangement, and use their eccentric motion to obtain reduction. The prototype achieved a measured overall reduction of 84:1 across twelve printed iterations. Torque-output testing remained incomplete.
The mechanism I wanted to explore
The central question was whether a different disk-and-pin arrangement could turn eccentric motion into useful output reduction without the traditional inner lobes. I moved from an early conventional cycloidal prototype to two pinned disks arranged across two stages, exploring how their coupled motion could drive the output.
This was an experimental mechanism study for a robotic drivetrain. The measured 84:1 ratio describes the prototype’s input-to-output rotation relationship; it does not establish its efficiency or torque capacity.
From CAD to the bench
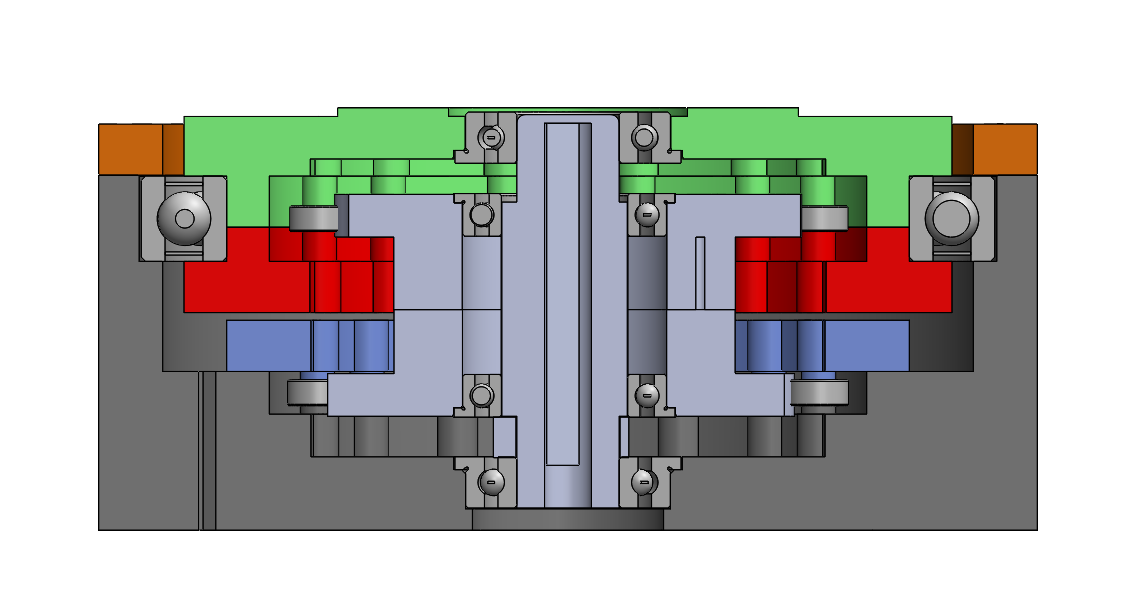
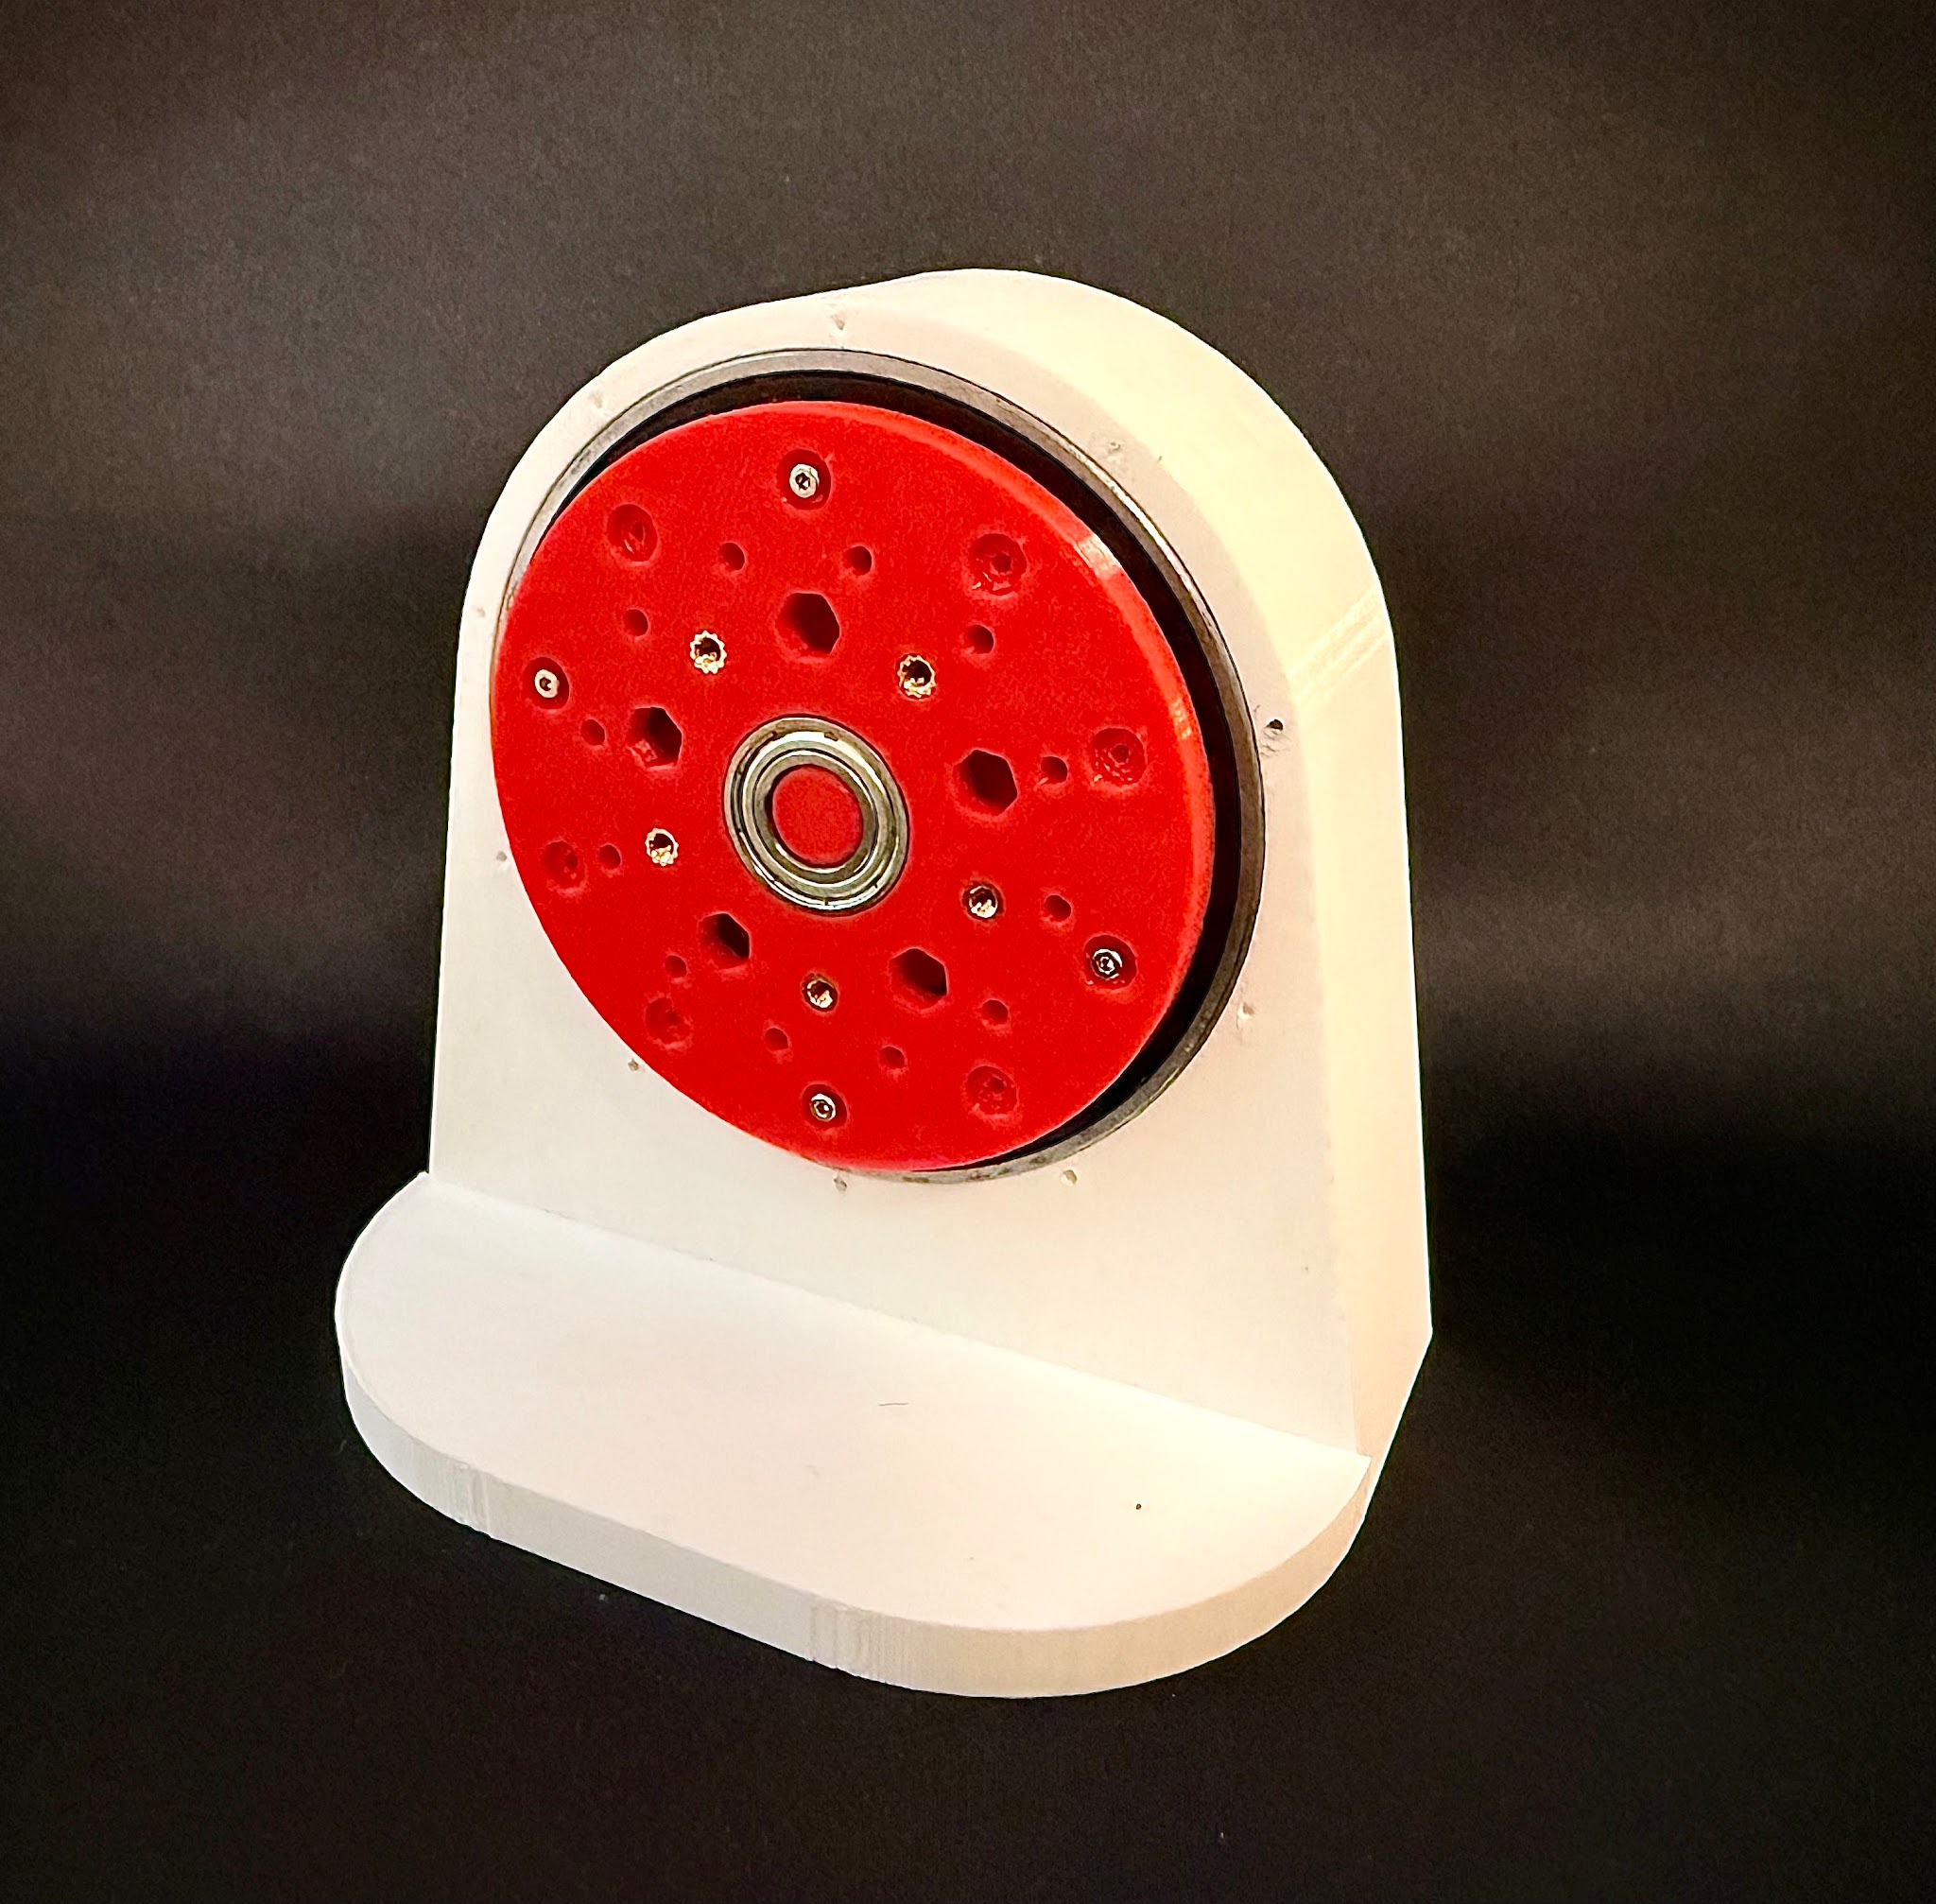
I modeled the disks, pin carriers, bearing seats, motor mount, and output assembly in SolidWorks, then fabricated PLA parts with FDM printing. The test setup used a NEMA-17 stepper, Arduino, and A4988 driver.
What the prototype taught me
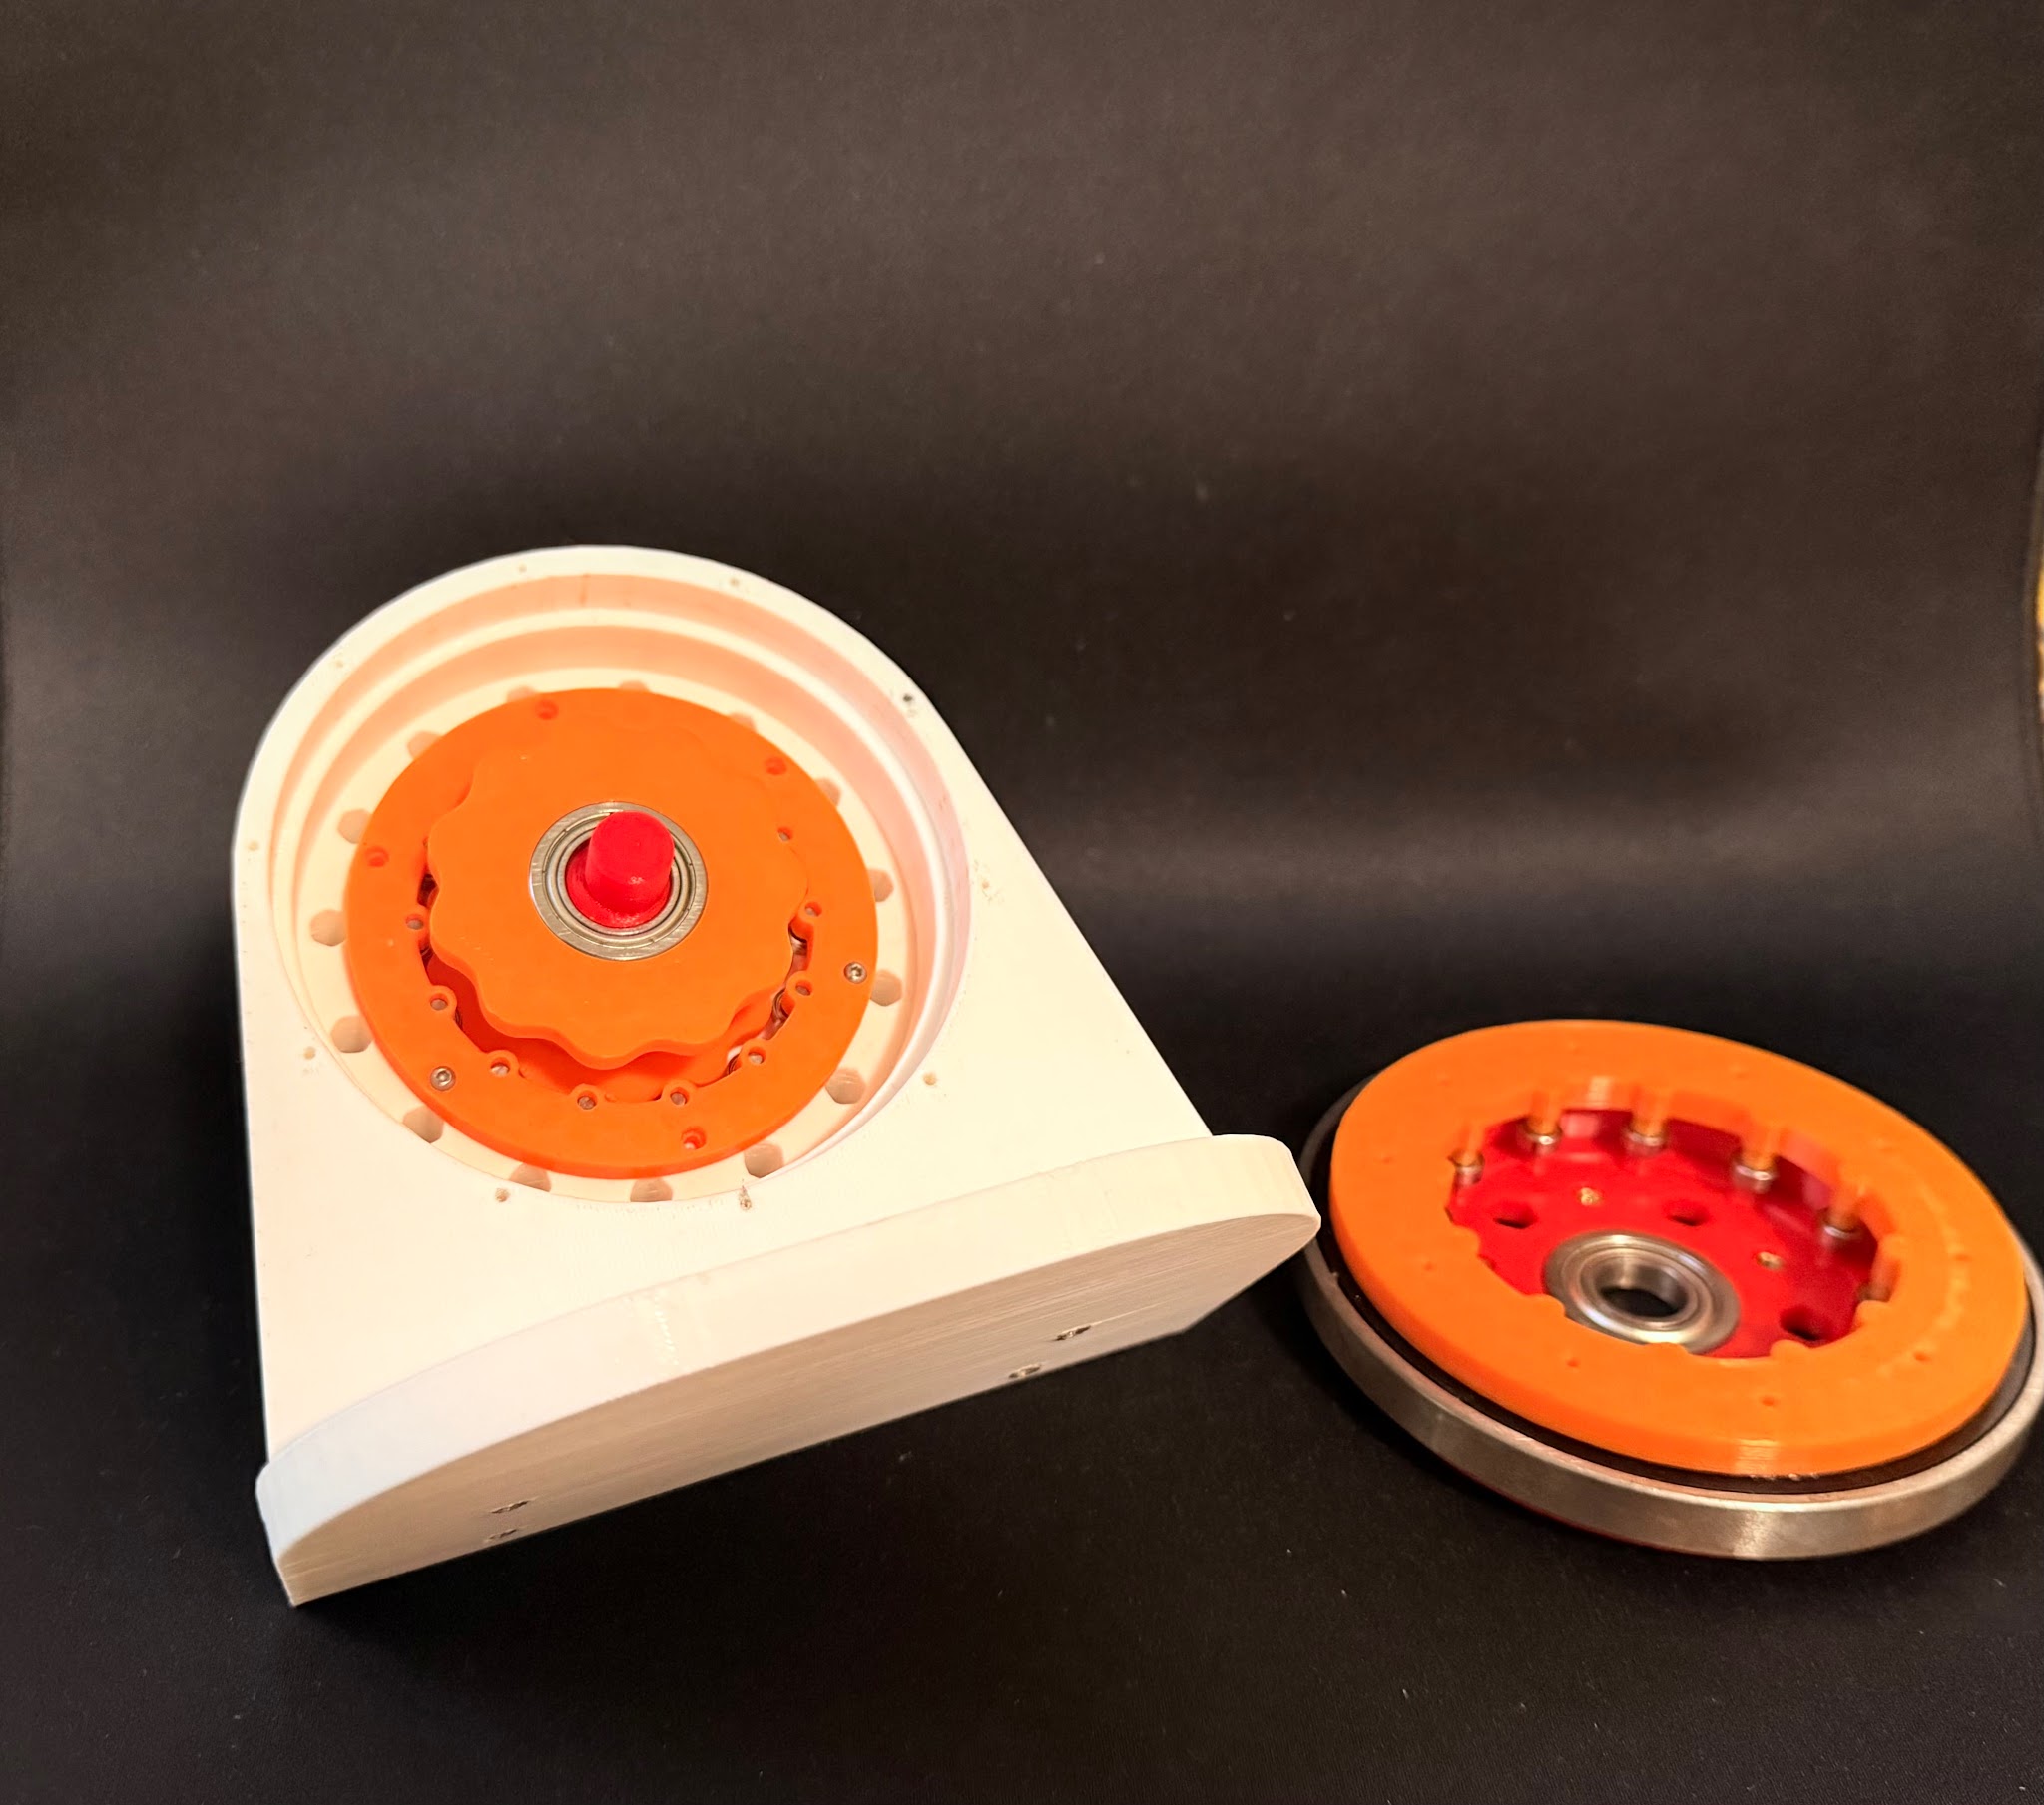
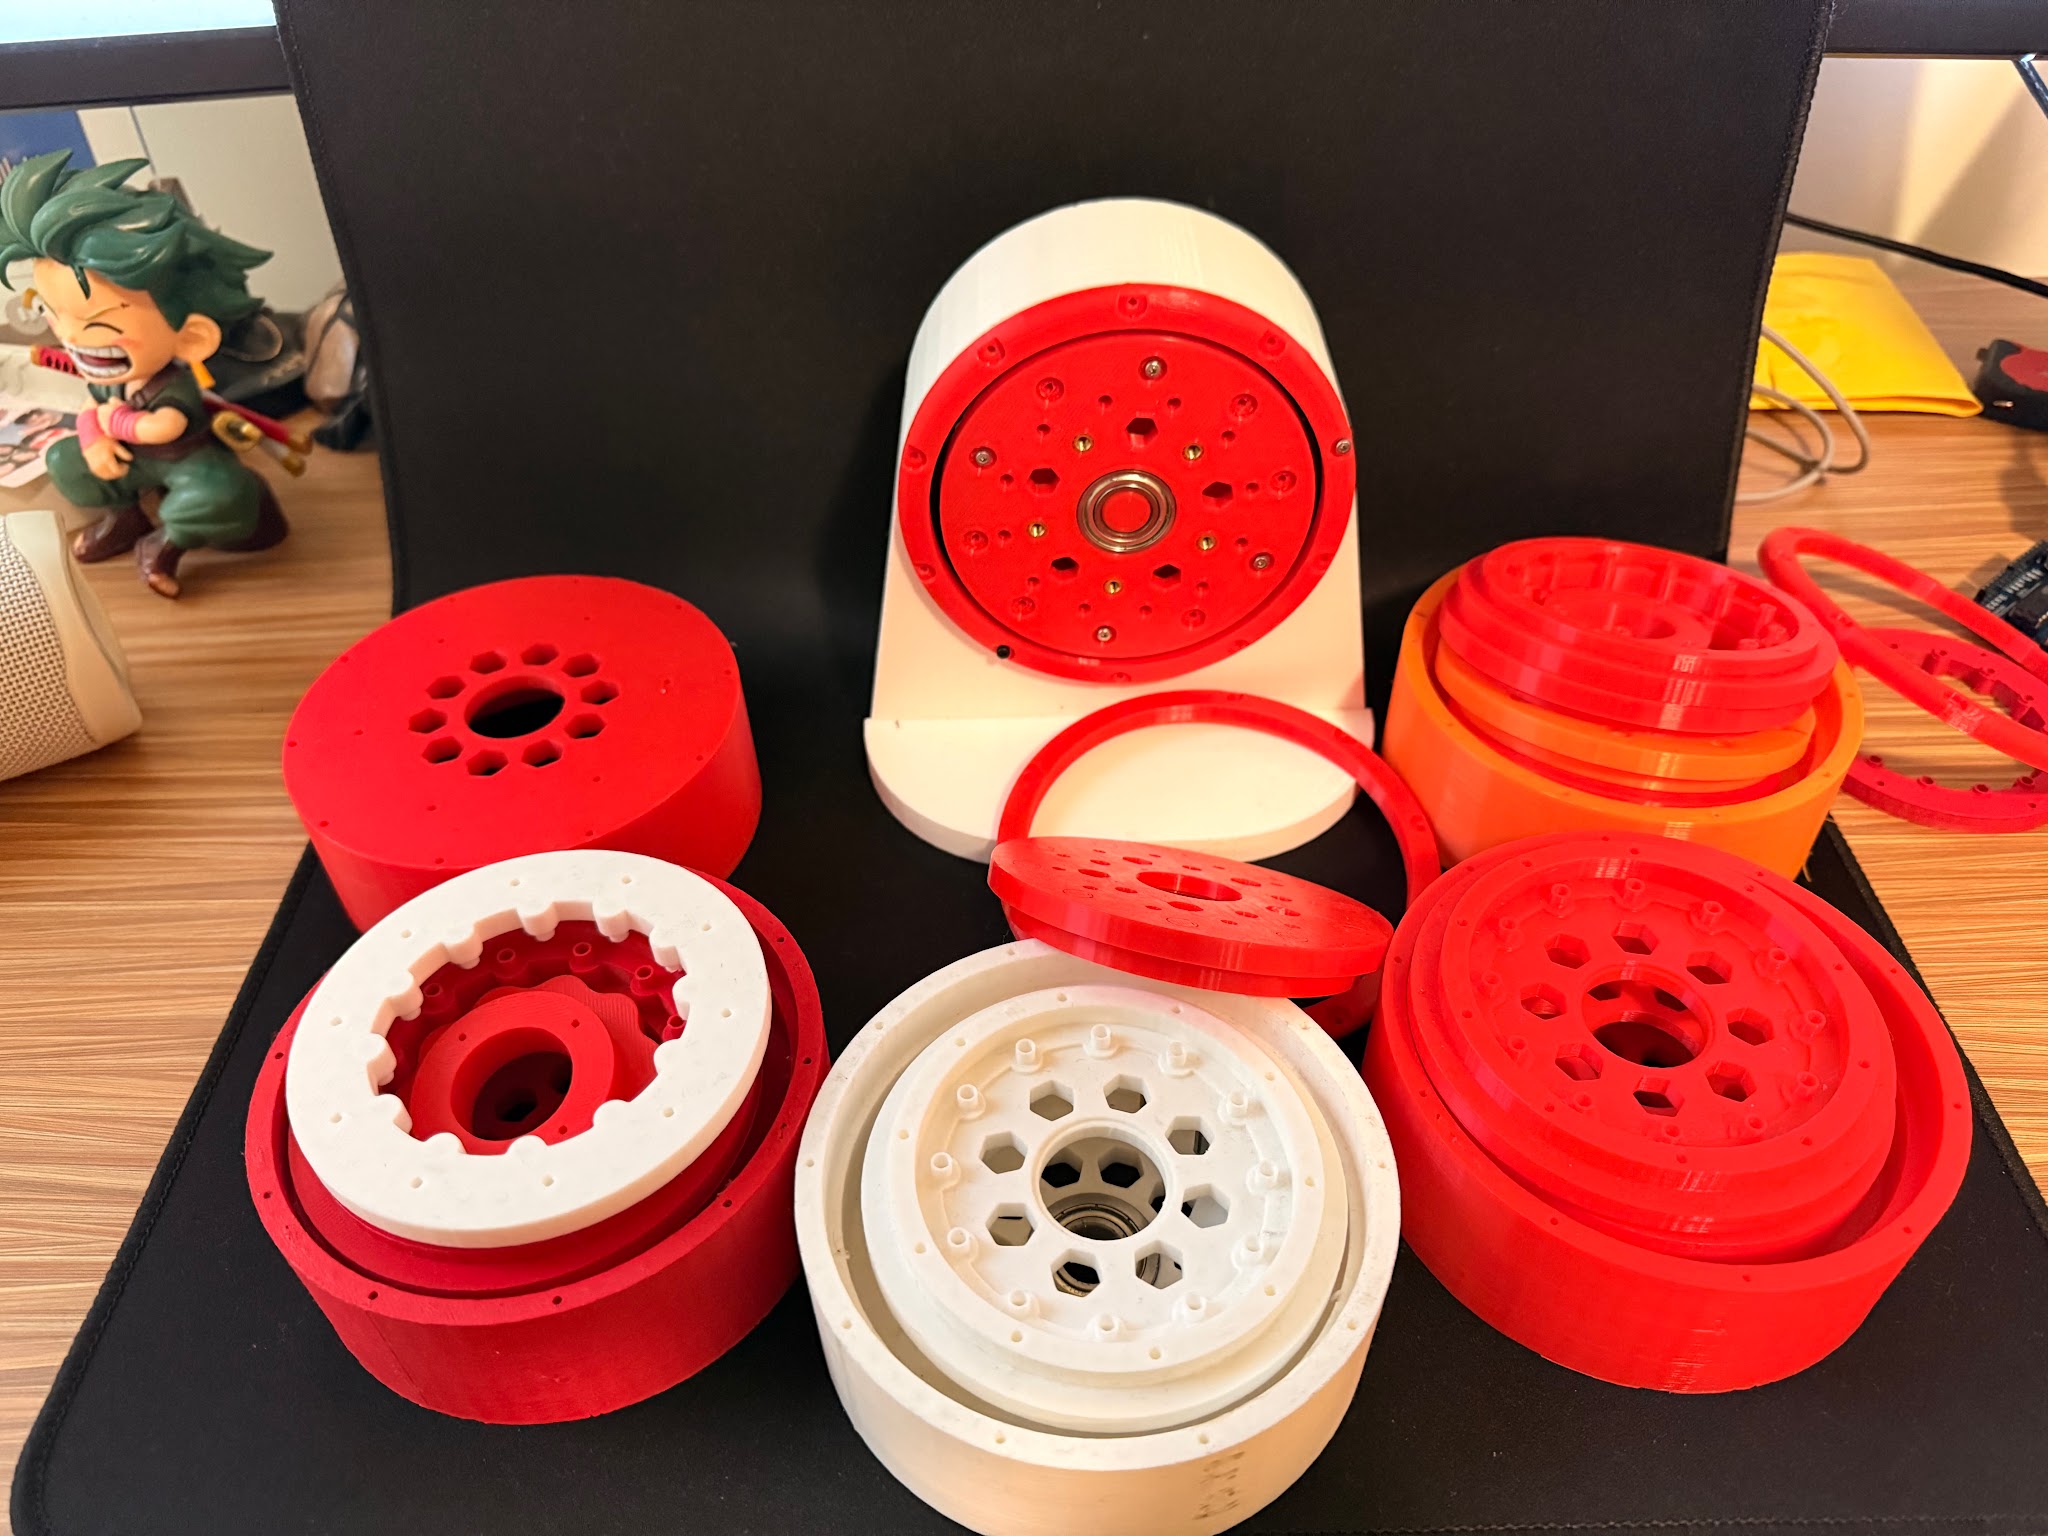
Early parts bound in the output stage. Changing printers required another tolerance adjustment. Added clearance finally produced motion, but also intermittent engagement and roughly 9° of measured backlash in that iteration.
I progressively added tape to the disks to reduce clearance, working back from the binding point to investigate its effect on engagement. That experiment made the tradeoff between free motion and lost motion tangible.
Project status
About two months into this project, an apartment fire destroyed my belongings, including the prototype, and brought development to an unexpected end.
Work on this prototype ended before torque-output and further performance testing could be completed. The project demonstrated assembly and motion, but its torque capability was not validated.
I’m now applying those lessons to a two-stage planetary gearbox for the shoulder of a desktop robot arm.
Engineering takeaways
Transmission design and bearing constraints
I learned to design the eccentric input, cycloidal disks, pins, and output as one assembly. Bearing selection required considering radial and axial loads, shaft and housing fits, retention, and available space. Locating the parts securely while preserving their intended motion was central to limiting binding.
Printed fits, friction, and backlash
Changing printers required another tolerance adjustment. Added clearance enabled motion but introduced intermittent engagement and roughly 9° of backlash in one iteration. Adding tape to the disks let me investigate engagement without printing another complete assembly.
Design for assembly and iteration
The project taught me to plan bearing installation, shaft and pin insertion, axial retention, and fastener access alongside the CAD. A gearbox needs to be practical to assemble and disassemble as well as capable of transmitting motion.
Separate demonstrated results from untested performance
The prototype demonstrated an 84:1 measured reduction across twelve printed iterations. Output torque and efficiency were not measured. Motion, backlash, and load capacity require separate tests; the gear ratio alone does not establish usable torque.